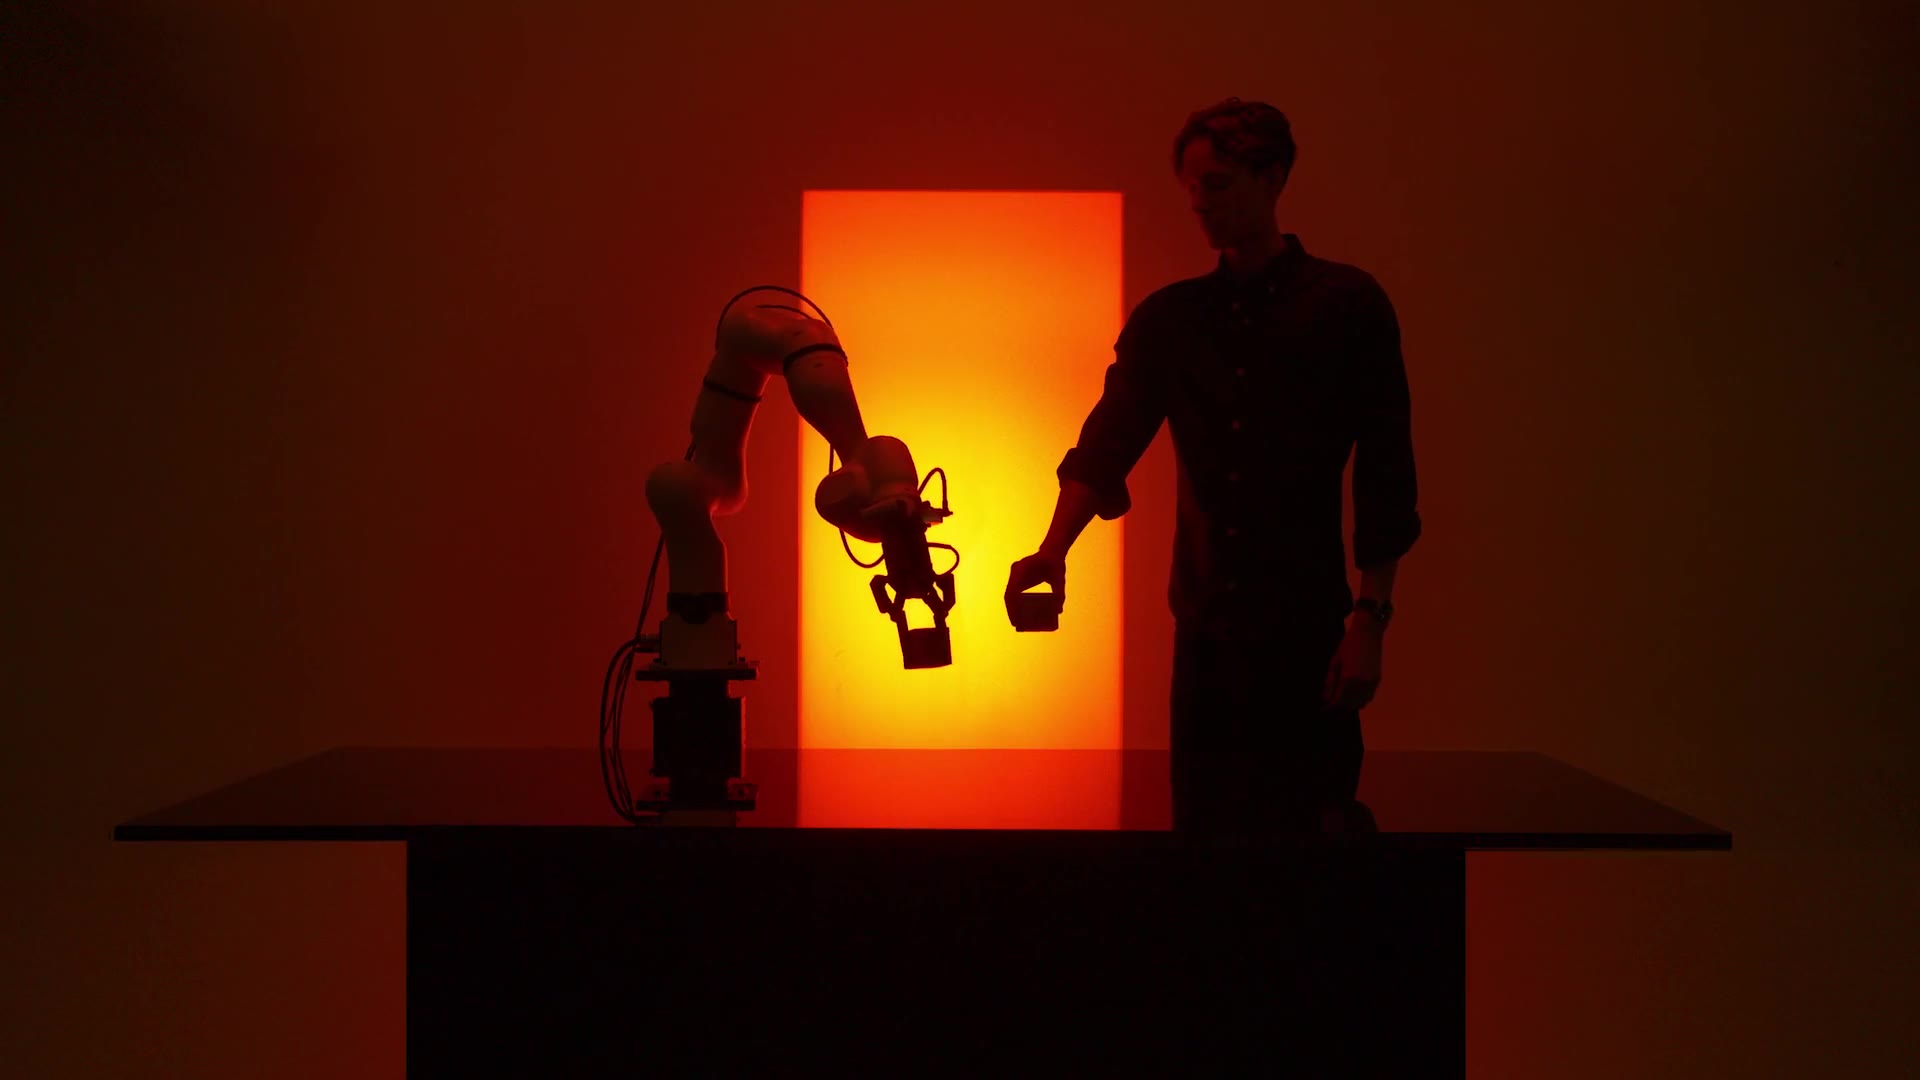
Learning over data
Instead of collecting ever more demonstrations for every task, we train one model to pick up a new task from a single example.
We're a frontier AI company, building a new kind of robot foundation model. One demonstration, no further training. Welcome to the era of Instant Robot Learning.
Show a robot a task once. Watch it work. Teaching a robot something new has always meant weeks of real-world data collection and training. We've built the first robot foundation model that has learned how to learn. Give it a single demonstration and it performs the task, with no further training.
Pre-trained on endless variety, entirely in simulation. Not a single pixel of real-world data.
Show the task once. That single demonstration is the whole dataset.
One model, any robot. It performs the task straight away, with no further training.
The same model, on objects it had never seen before, across robot arms, bimanual systems and humanoids. Every task was demonstrated a single time by a person, then carried out by the robot.
Our goal is to close the gap between buying a robot and getting useful work out of it, from months to minutes.
Instead of collecting ever more demonstrations for every task, we train one model to pick up a new task from a single example.
Simulation creates more variety than the real world ever could, across objects, tasks, layouts and robot bodies. The model learns there, so one real example is enough here.
When learning is instant, teaching becomes iteration. Show a task, watch the result, adjust and show it again. That's how the team found a double handover that flips a shoe the right way round.
Read the research behind our first model, or follow along as we build.